


DELTA-TECH designs and manufactures custom 3D vision-guided robotic cells for the automatic recognition, gripping and accurate transfer of randomly arranged parts. We integrate machine vision, robotics, a task-specific gripper and control software into one system tailored to the production process.

Manual separation and feeding of randomly arranged or bulk parts can be repetitive and difficult to plan. A 3D Bin Picking system detects the position and spatial orientation of individual parts, selects a suitable gripping point and uses a robot to place the workpiece in the position required by the next operation.
Each solution is adapted to the part geometry, surface, weight, bin design and required production cycle.
The camera system captures the spatial data of the parts in the bin and generates a processable 3D representation.
The system identifies accessible parts and determines their position and orientation.
The control system selects a suitable grip point and considers reachability and potential collision risks.
The robot safely removes the part using a task-specific gripper.
The workpiece is transferred to the next manufacturing, assembly, inspection or packaging operation.
The robot, vision system and gripper are selected according to the part, environment, required process and customer standards—not simply by brand.
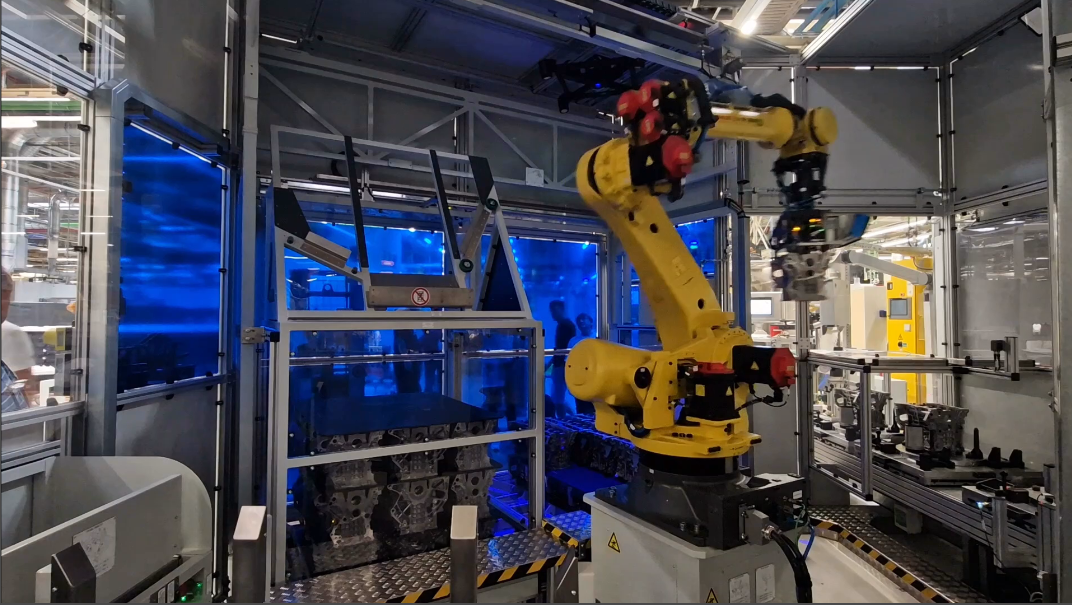
The DELTA DFC-2000 3D vision-guided robotic block placement station demonstrates DELTA-TECH’s in-house development and integration expertise. The system won first place at the 2025 Machine of the Year competition in the Material Handling and Storage Machinery category.
A DELTA-TECH másik 2025-ös kategóriagyőztes saját fejlesztése a DELTA FS-600 optikai porozitásvizsgáló állomás hengerfuratokhoz.
External industry article: EPLM / Enterprise Group
A győri kutatás-fejlesztési központunkban épített robotos demonstrációs cella a Pickit rendszerével ömlesztett alkatrészek felismerését, megfogását és automatizált kezelését mutatja be.
A fejlesztés szakmai bemutatása a Műszaki Magazinban →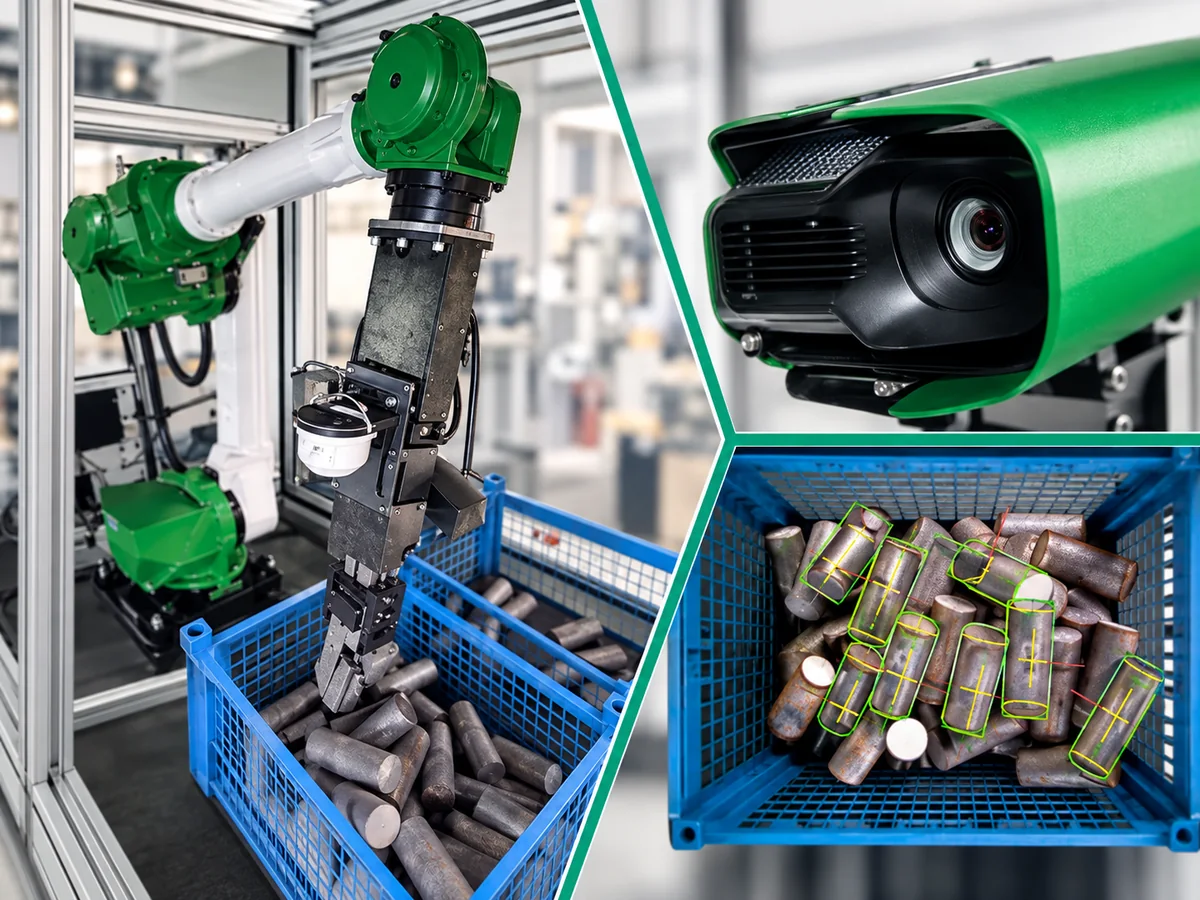
DELTA-TECH can manage the complete implementation process. The exact technical scope and performance targets are agreed jointly for each project.
Suitability depends on factors including geometry, weight, surface, reliable gripping and the tendency of parts to become entangled. A sample part, 3D model and information about the loading conditions are required for a definitive assessment.
A part drawing or 3D model, sample parts, bin dimensions and filling method, required input and output positions, target cycle time and available installation space.
Yes. Following an on-site and controls assessment, the cell can be connected to existing equipment and production data interfaces.
Components are selected according to the application and customer standards. DELTA-TECH has experience integrating industrial robots from several manufacturers as well as 2D and 3D vision systems.
Not always. However, with randomly arranged parts, a gripping concept adapted to the product and its possible pick poses is one of the keys to reliable operation.
Through early part assessment, gripping trials, simulation and a clear definition of the required process. A dedicated feasibility test is recommended for complex applications.
Send us the part drawing or 3D model, bin data and a short description of the intended process. Our engineers will conduct a preliminary assessment of whether 3D Bin Picking is suitable for the application.
Personal technical consultation and quotation requestTechnical information submitted through the form is sent directly to István Tóth. You can also contact him by phone or email.
DELTA-TECH technical contact
Based on a short technical description, our colleagues will contact you and work with you to determine the appropriate solution direction.